Hardware · Navigation and inertial
Pollux 3 INS-GNSS
Micro-miniature Inertial Navigation system
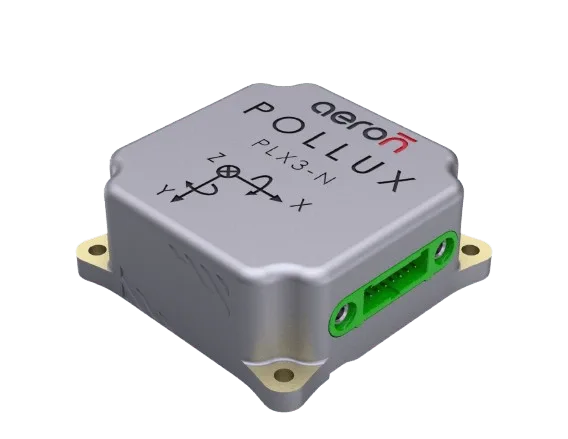
Overview
Aeron's Pollux 3 is a family of highly compact MEMS-based Inertial Navigation Systems, running an Extended Kalman Filter for near-tactical performance in a package small enough for UAVs, UGVs, and other unmanned systems where size and power are tightly constrained.
Aeron's Pollux 3 is a family of highly compact MEMS-based Inertial Navigation Systems. The system runs an Extended Kalman Filter (EKF), offering near-tactical performance and providing the best estimates of navigation parameters — including position, velocities, attitude, and heading. Pollux 3 features tri-axial MEMS solid-state accelerometers, tri-axial gyroscopes, a tri-axial magnetometer for heading measurement, and an integrated multi-constellation GNSS.
Pollux 3 is a miniature, low-powered INS well suited for UAVs, UGVs, and other unmanned systems where size is a constraint. This strap-down system is designed to perform in highly dynamic situations, delivering precise attitude, heading, and position information over serial RS232 and UART TTL ports at a navigation output rate of 200 Hz.
Pollux 3 is a micro-miniature MEMS-based inertial navigation system combining tri-axial accelerometers, gyroscopes and a magnetometer with an integrated multi-constellation GNSS receiver. An Extended Kalman Filter estimates position, velocity, attitude and heading, with navigation output at 200 Hz. It weighs ~38 g, draws <1.5 W and suits navigation and control of UAVs, UGVs and other unmanned systems.
MIL-STD-810G · IP65
Key features
- Extended Kalman Filter sensor-fusion engine
- Tri-axial MEMS accelerometers, gyroscopes & magnetometer
- Integrated multi-constellation GNSS (GPS, GLONASS, Galileo, BeiDou, NavIC)
- Jamming & spoofing detection on the GNSS receiver
- User-configurable dynamic range up to ±2000°/s and ±40 g
- Weighs ~38 g — built for size-constrained unmanned platforms
Features
- With DriftLocTM. When satellites vanish in tunnels, urban canyons, or interference zones, it holds an accurate position and true heading by minimising INS drift.
- Compact, Tiny SWaP. Miniature 37 (L) × 37 (W) × 15 (H) mm footprint at ~38 g, drawing under 1.5 W — built for size- and power-constrained unmanned platforms.
- High Accuracy. 1.5 m CEP position accuracy and 0.1 m/s horizontal velocity accuracy (1σ) with integrated multi-constellation GNSS, including jamming and spoofing detection.
- Lightweight. Weighs approximately 38 g, suitable for micro-UAV applications while remaining ruggedized for demanding operating environments.
- High Quality Sensors. Uses high-quality MEMS gyros for near-tactical performance and usable GNSS-denied performance during short-term outages.
- MIL Qualified. Complied to MIL-STD-810G to perform reliably in extreme outdoor environments of temperature and vibration.
- Rugged Design. Ruggedized construction built to withstand the shocks and vibration typical of real-world unmanned-platform operation, such as quadcopter landings.
- Extended Kalman Filter. Offers near-tactical performance, providing the best estimates of navigation parameters during short-term GNSS outages.
- Superior Ingress Protection. IP65 compliant, able to endure water spray and rain — a reliable solution even when externally mounted.
- Communication. Standard RS232 and UART TTL interfaces plus SPI/I²C for external airspeed and magnetometer aiding input, for easy integration with autopilot systems and controllers.
Applications
- Drone and UAV Navigation
- Autonomous Control and ADAS