Hardware · Navigation and inertial
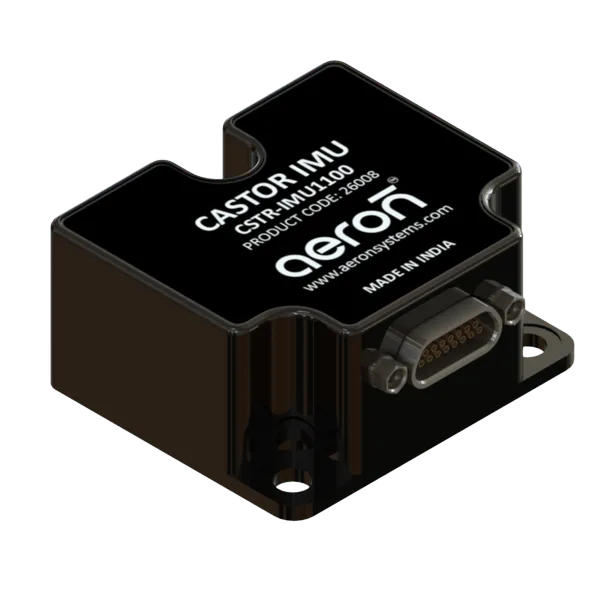
Castor IMU 1100
Miniature Tactical 6DOF IMU with RS422 Interface
Updated
Overview
The Castor series CSTR-IMU1100 is a high-end tactical class inertial measurement unit consisting of high-performance tri-axial accelerometer, tri-axial gyroscope, and tri-axial inclinometer sensors based on the latest MEMS technology, delivering control-grade inertial measurement data over an RS422 interface.
Its rugged and modular design, with output available over an RS422 interface, makes the IMU 1100 suitable for integration with control computers and other application hardware in guidance, navigation, and control systems, robotics and gimbal control, unmanned ground vehicles, and flight control systems.
Model code: CSTR-IMU1100 · Product code: 26008
Key features
- High-end Tactical Gyro Performance. Excellent 0.7 deg/hr (typically) in-run bias instability, thermal compensation, and good short-term turn-on to turn-on repeatability.
- Digital Software Filtering. IMU1100 features configurable filters with programmable taps optimising the IMU for best performance.
- Fully Calibrated. Factory calibrated for misalignment, offsets, and scale factor errors and temperature compensated.
- High Shock Survival. IMU1100 is designed for shock survival up to 1500g making it suitable for high dynamics applications.
- Communication. RS422 Interface, external trigger, diagnostics, and data ready options for integrated communication with user controller.
- High Update Rate. Offers update rates of up to 2000Hz and configurable bandwidth as per customer application requirements.
- Operating Voltage. Low supply voltage requirement making it possible to power up the IMU with low voltage battery systems.
- Low Noise Sensors. Low noise and highly stable accelerometer and gyroscope sensors for high performance sensor data.
- Operating Environment. Wide operating temperature range and temperature compensation of sensors for useful performance across operating range.
Applications
- Guidance, Navigation and Control
- Drone Navigation and Control